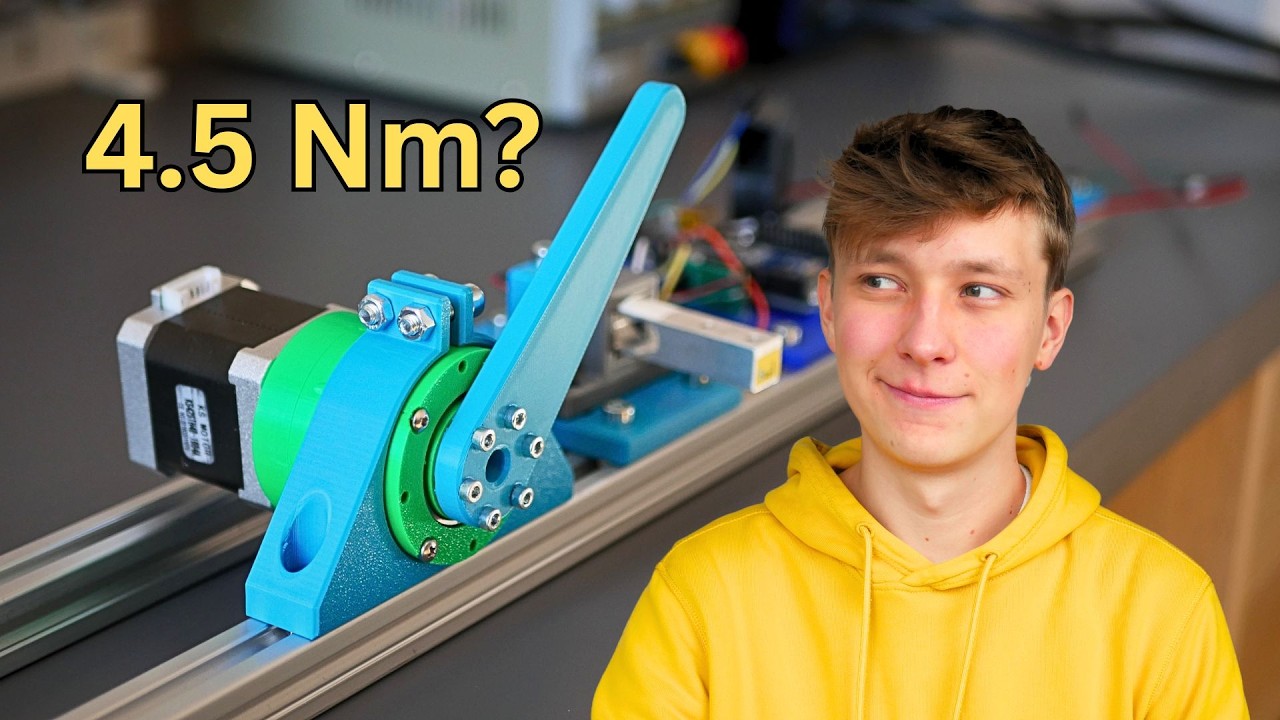
The video explores the feasibility of using 3D printed planetary gearboxes combined with cheap stepper motors as a cost-effective alternative for robotic arms, which are typically expensive due to their motors and gearboxes. The creator designed a compact planetary gearbox in Fusion 360, using PLA material for printing, and optimized the design through three iterations to achieve smooth operation and a 5:1 gear ratio. To increase torque, a second stage was added, resulting in a 25:1 reduction ratio. A custom test setup with a load cell, Arduino, and Python software was built to measure the torque and durability of the gearbox under stress.
Testing revealed that the 3D printed gearbox could handle a peak torque of about 4.5 Newton meters, with an efficiency of roughly 72% compared to the theoretical maximum torque. The gearbox was subjected to extensive durability tests, running over 33,000 cycles and nearly 48 hours continuously. Despite some wear and minor damage in the final stage, the gearbox performed impressively well, especially considering it was run without lubrication to push its limits. The first stage showed minimal wear, indicating potential for long-term use at moderate torque levels around 2 Newton meters.
The creator concluded that while 3D printed planetary gearboxes can work effectively for certain applications, they are not yet suitable for high-torque robotic arms that require heavy-duty motors and gearboxes. The small plastic gears tend to fail sooner under higher torque, limiting their use in demanding robotics projects. However, the gearbox design could be very useful for lighter robotics projects or other applications where moderate torque is sufficient. The creator also shared plans for an open-source robotic chassis designed with 3D printed parts, demonstrating the versatility and rapid prototyping capabilities of 3D printing.
In addition to the mechanical aspects, the video highlighted the integration of electronics and software, including Arduino programming and Python scripting, to control the motor and monitor torque in real-time. The creator recommended Skillshare classes for viewers interested in learning Arduino programming and Python, which were instrumental in developing the control system for the test setup. This educational segment emphasized the importance of combining mechanical design with software skills in robotics projects.
Finally, the creator showcased a working robot chassis assembled with the 3D printed gearboxes, stepper motors, and an Arduino Uno Q board, which supports programming in both Arduino and Python. The robot could be controlled remotely via a web interface, demonstrating precise and sharp movements suitable for applications like room mapping with ROS (Robot Operating System). The video ended with an invitation to viewers to subscribe for future updates and a suggestion to test commercially available gearboxes against the 3D printed version in upcoming content.